2023
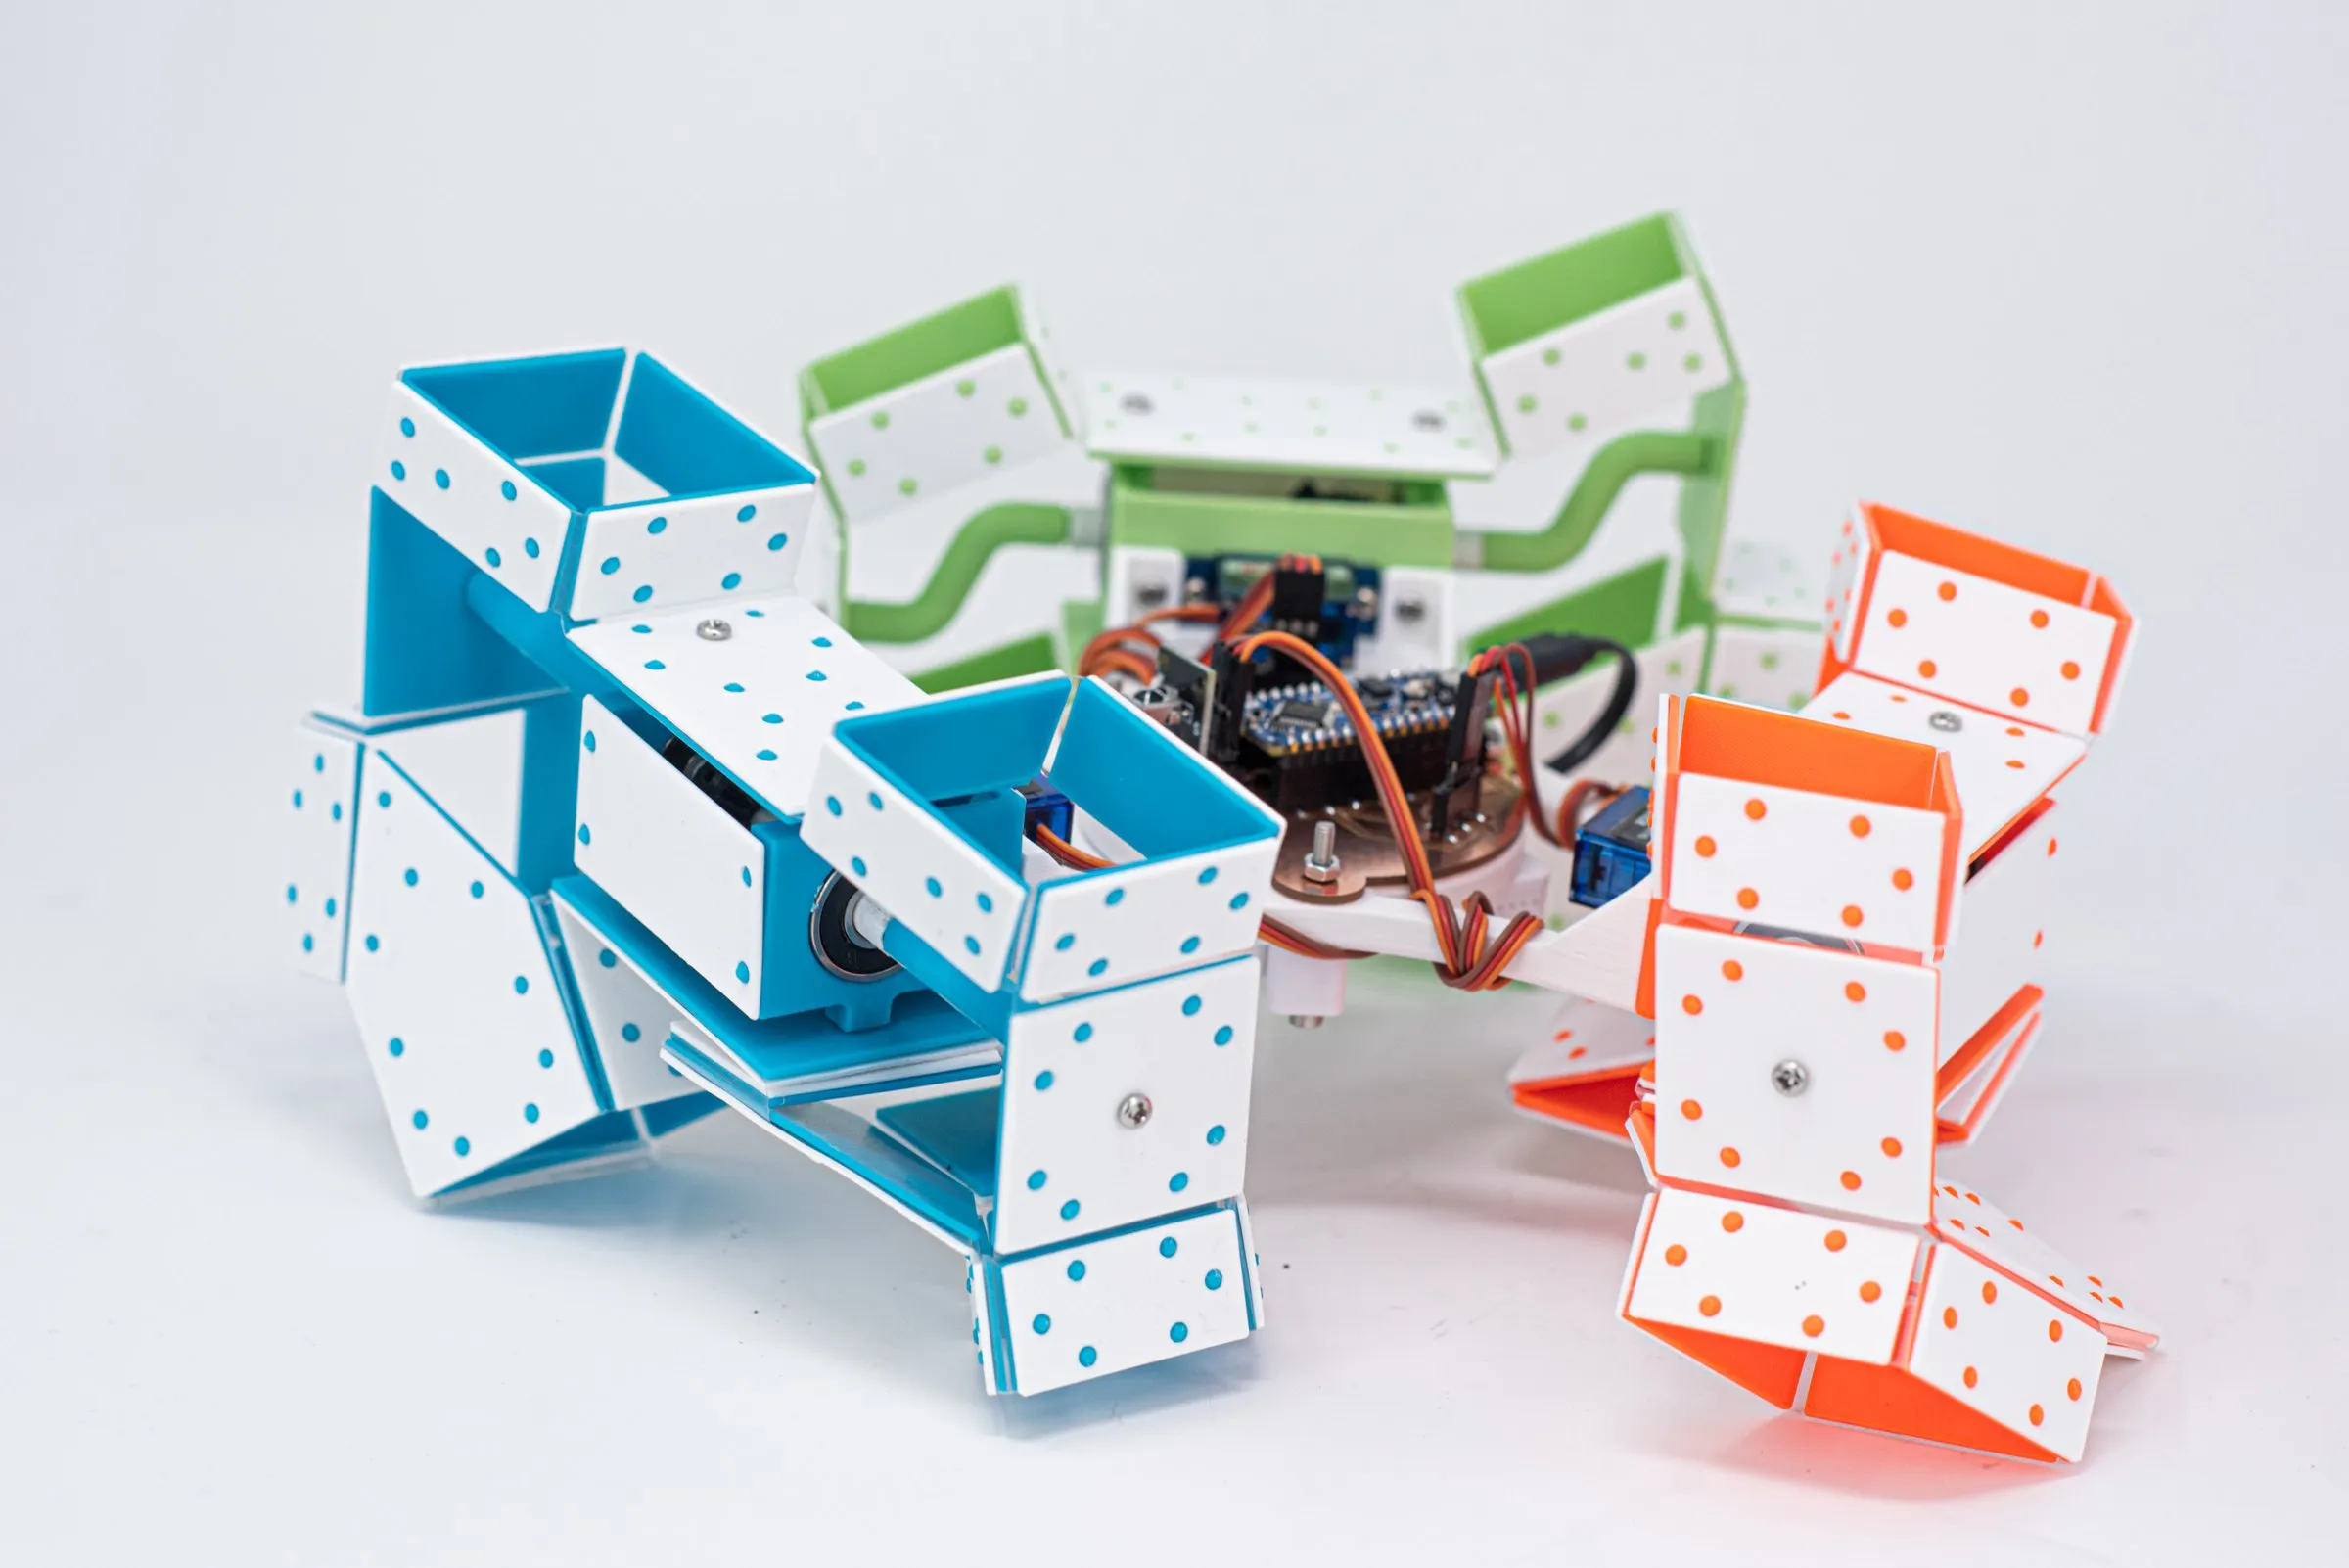
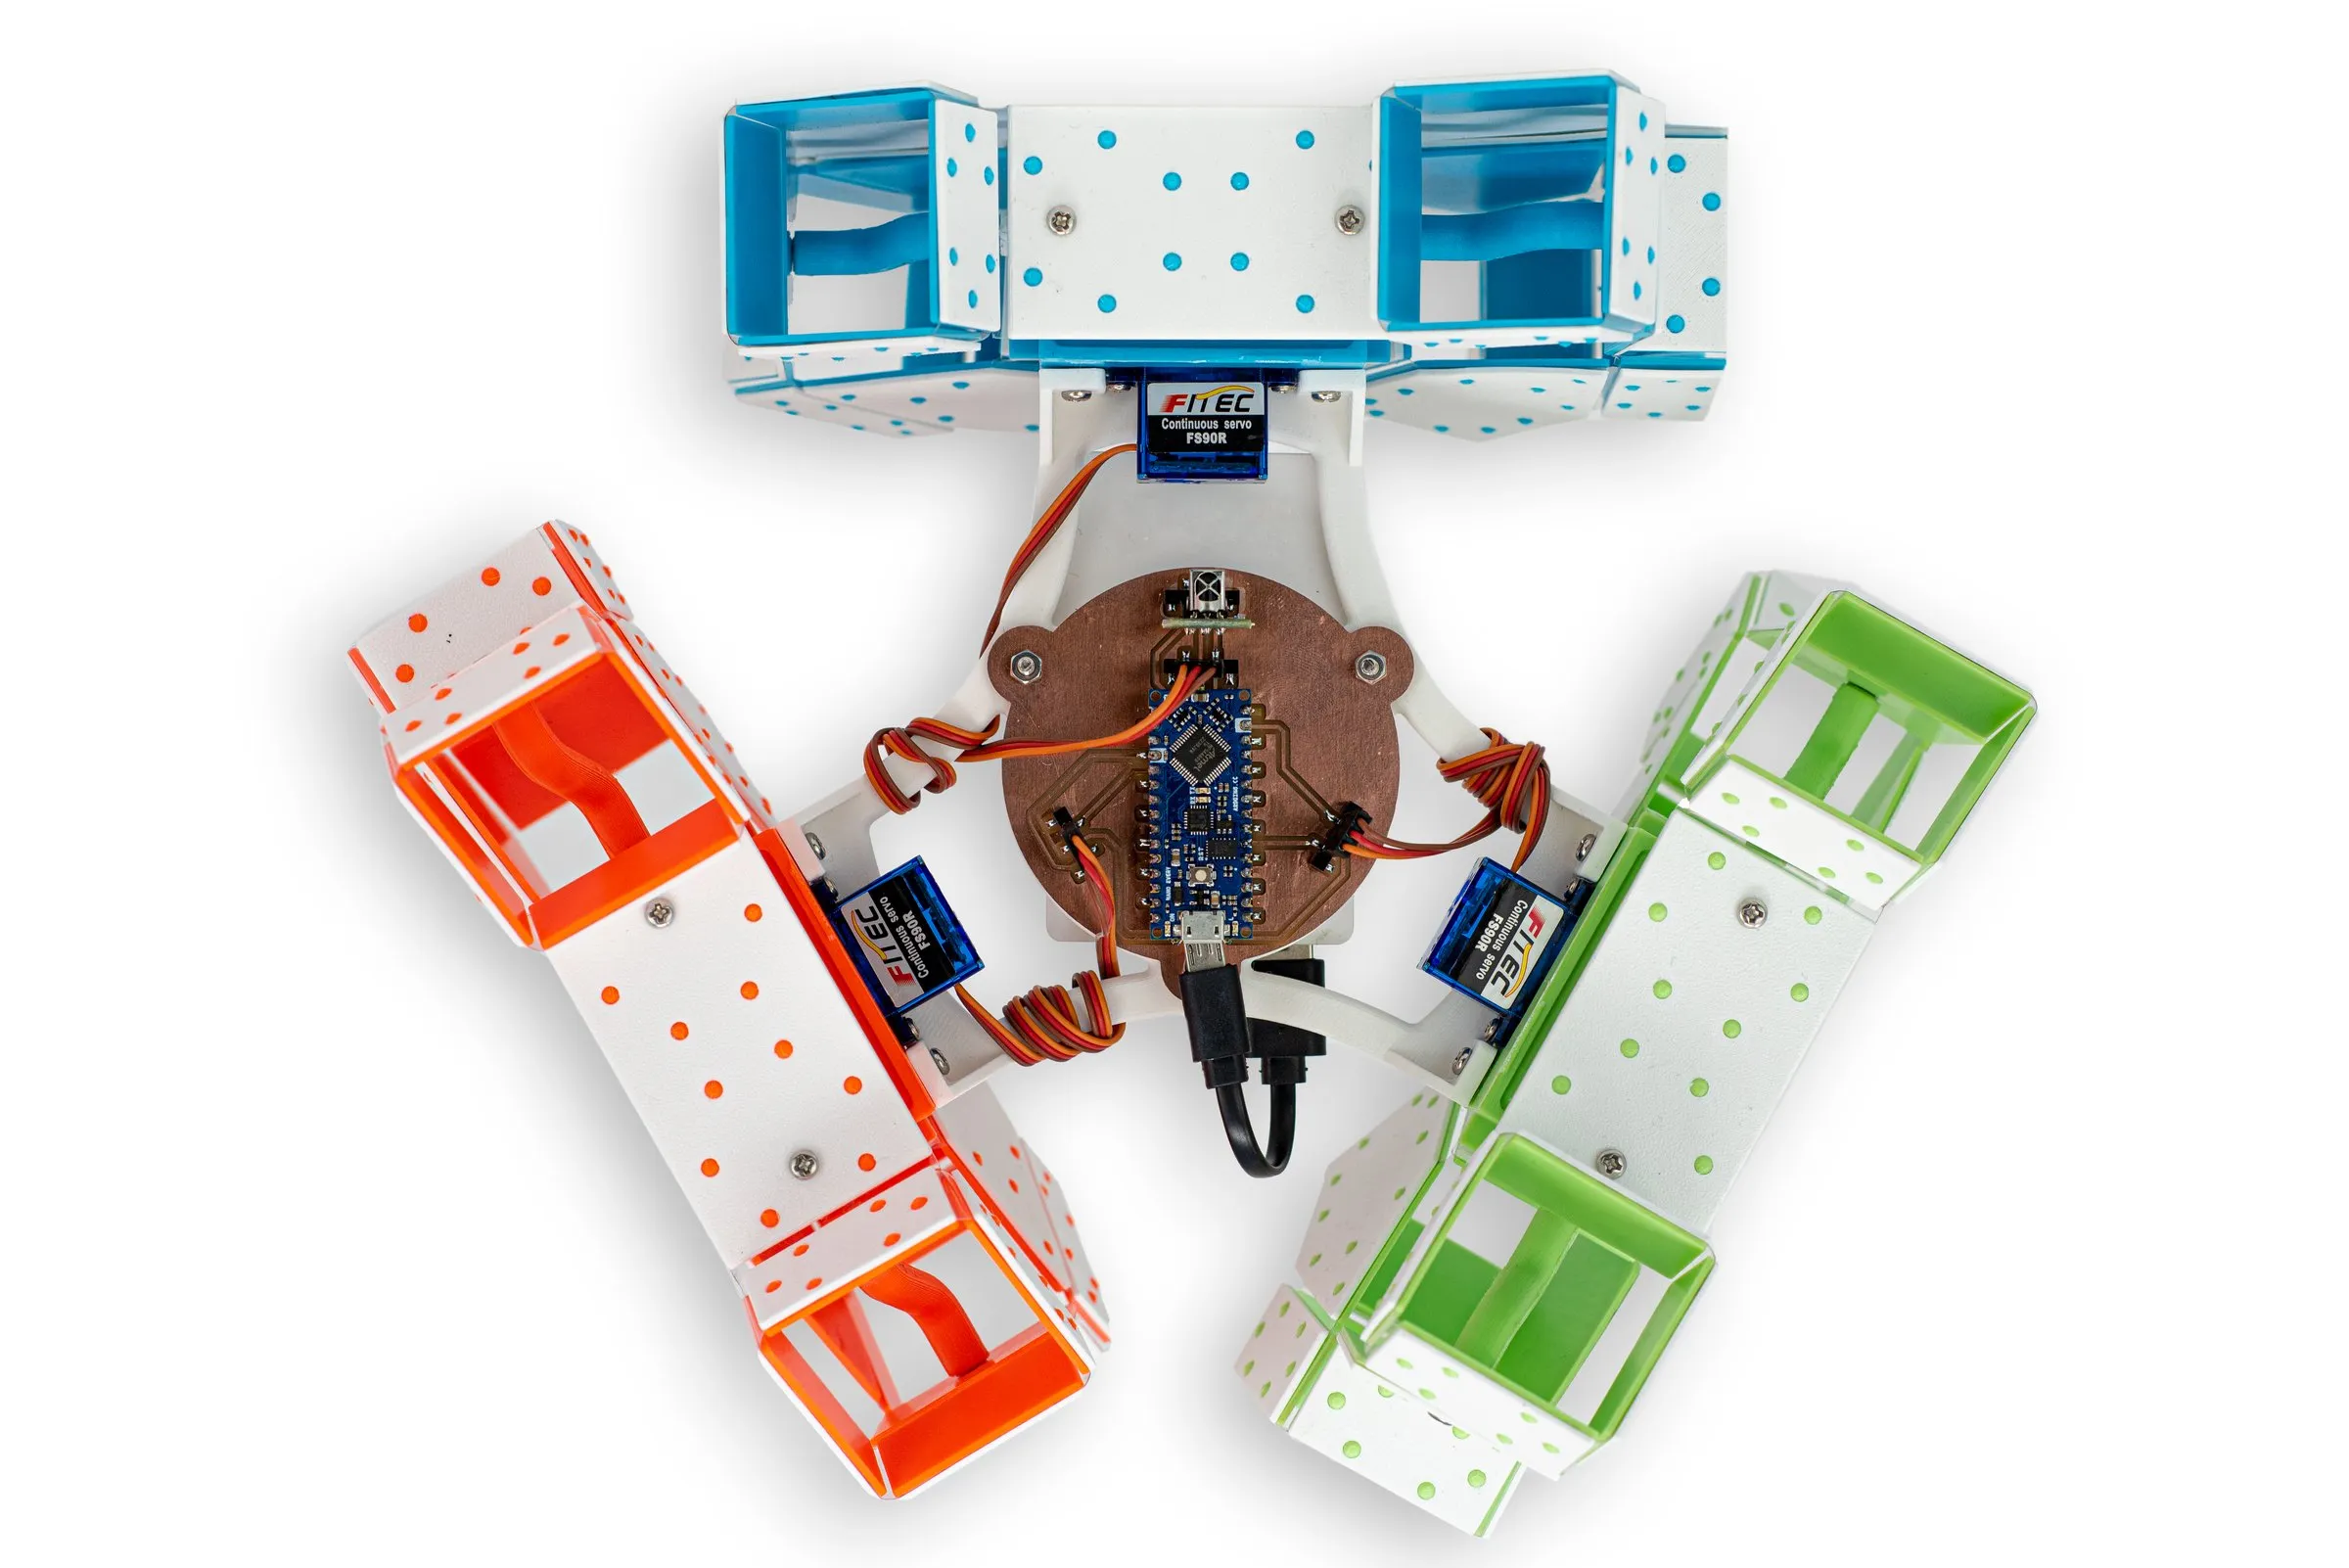
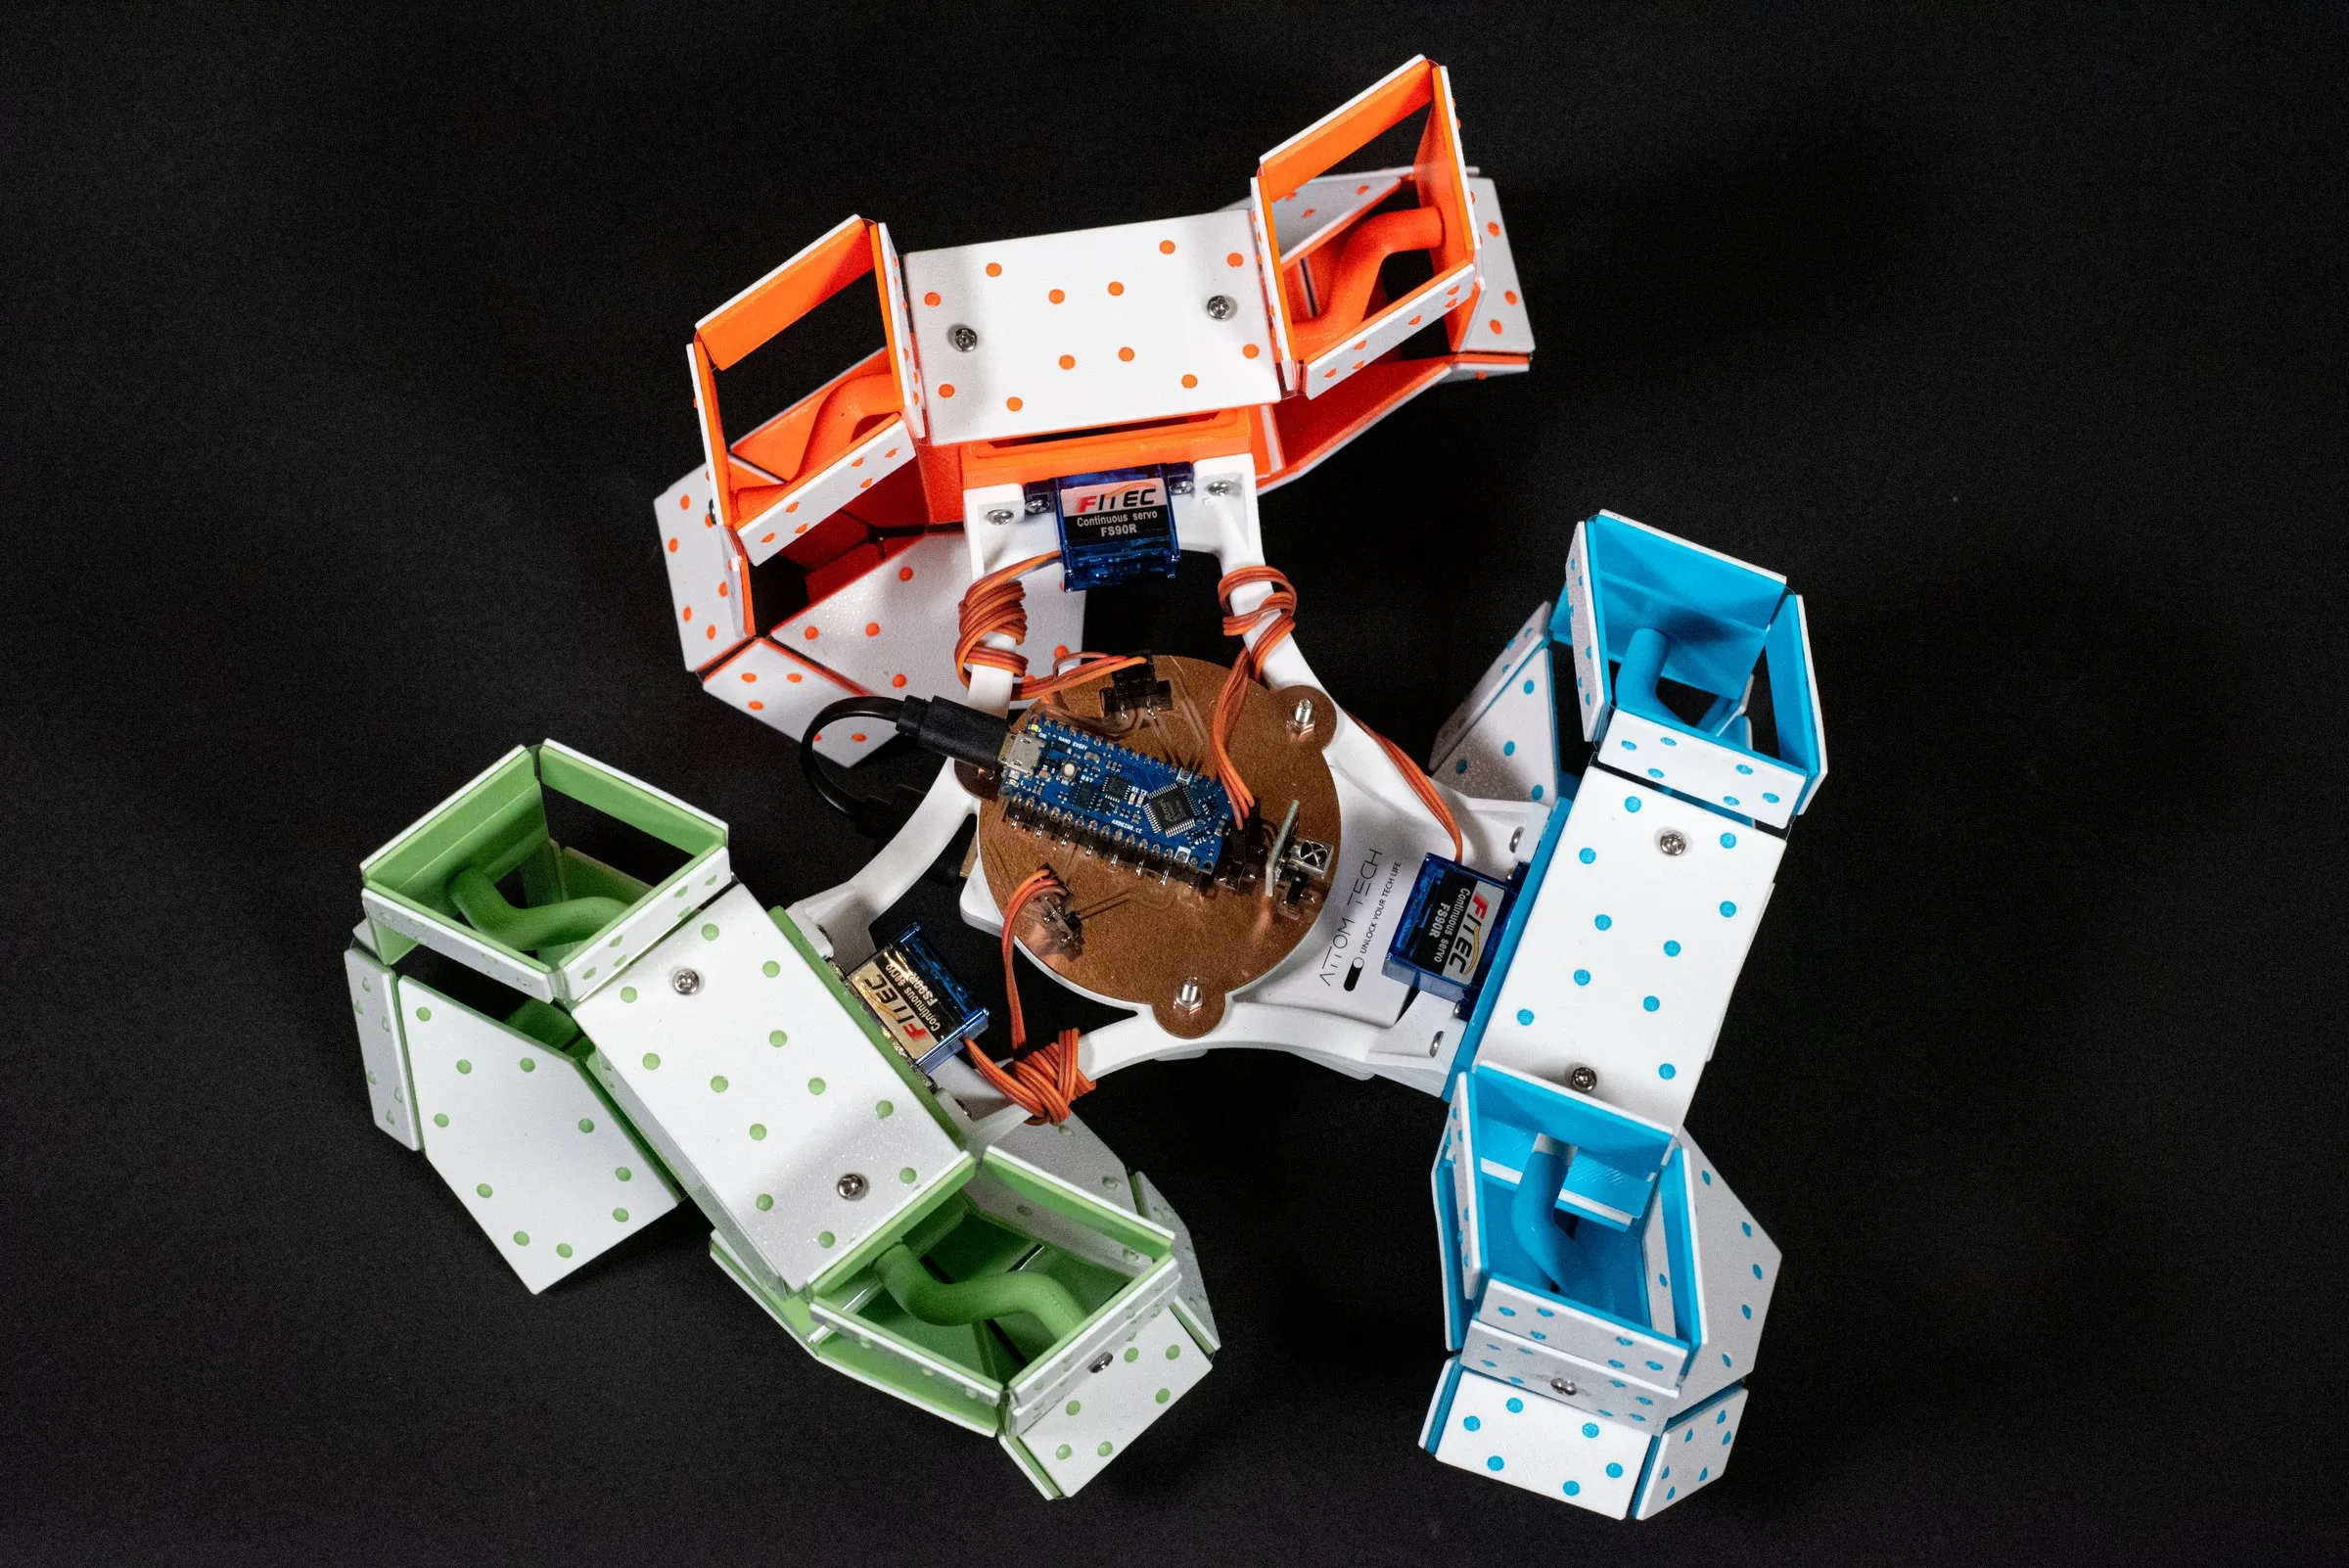
InverteBot
- Type
- "Informal" robot from a transformable prismatic structure
- Course
- SCI-6478 Informal Robotic
- Instructor
- Chuck Hoberman
- Duration
- 6 Weeks
- Team
- Kai Zhang, Claire Dorsett, Oskar Nilsson
Role
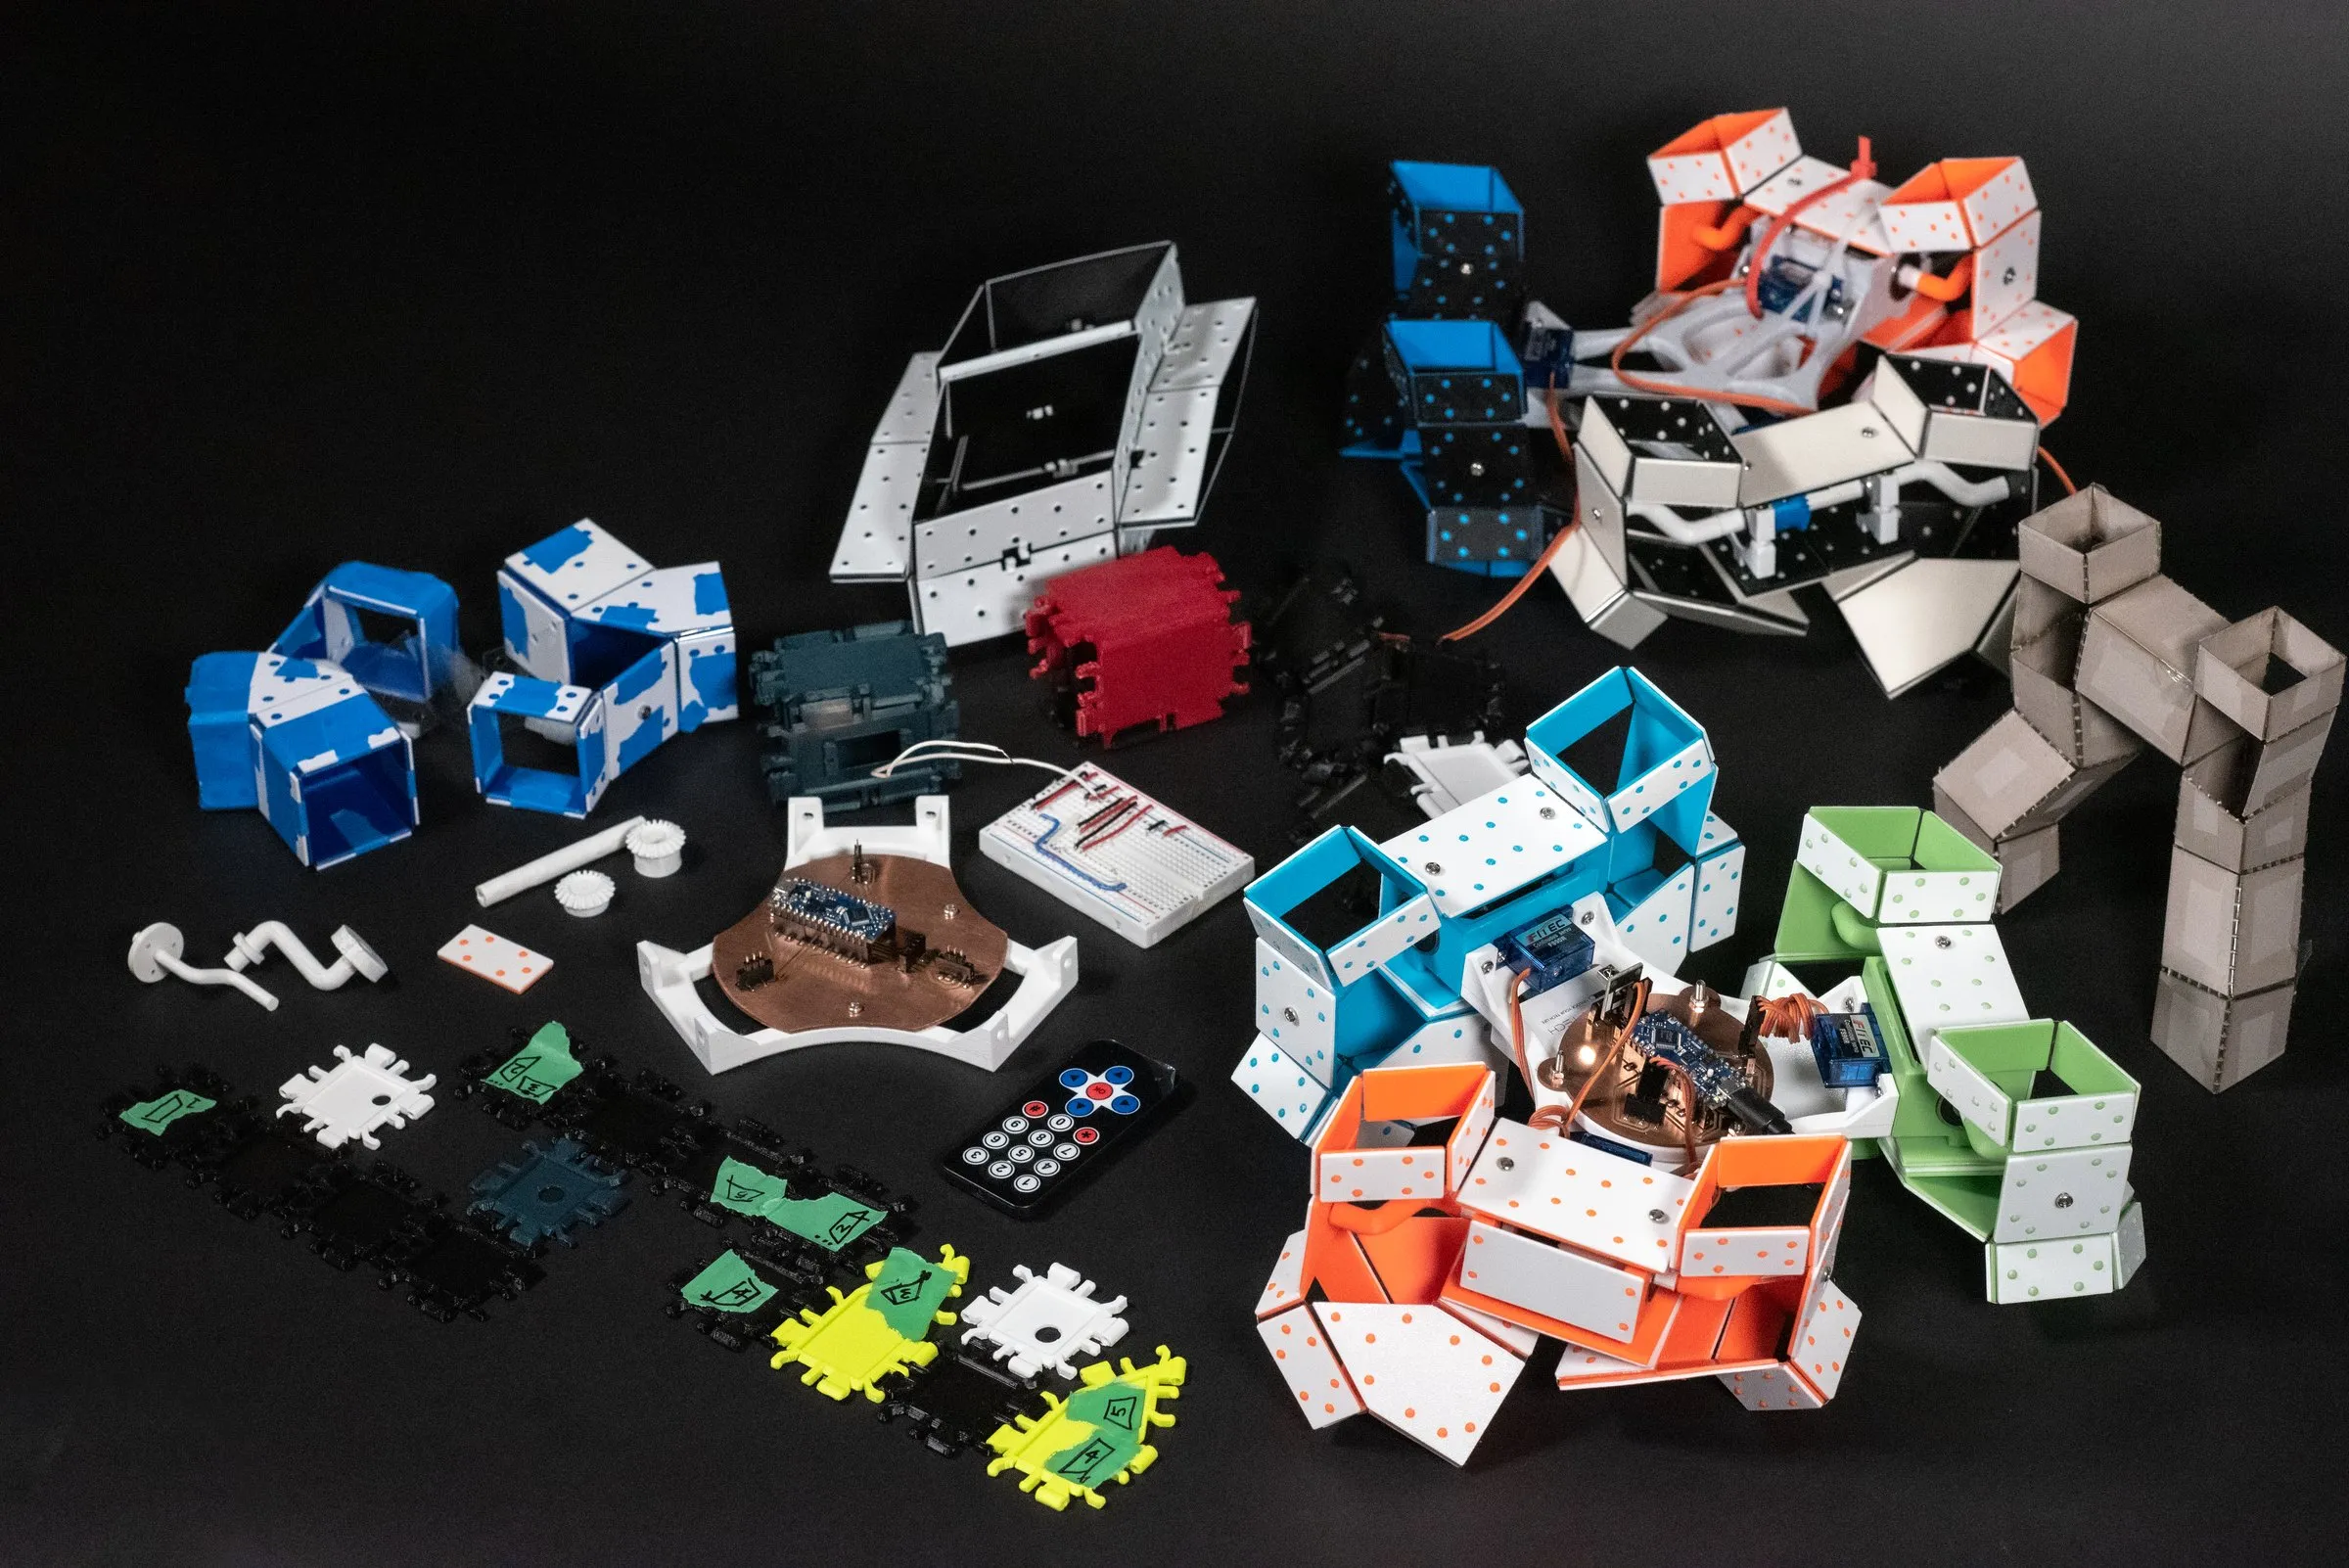
- Collaborated with Professor Hoberman to adapt the new fabrication method (3D-printed panels + Mylar) into the final production.
- Used Grasshopper to procedurally generate the whole robot and simulate its movement.
- Defined the final aesthetic and overall details, and prepared the production files.
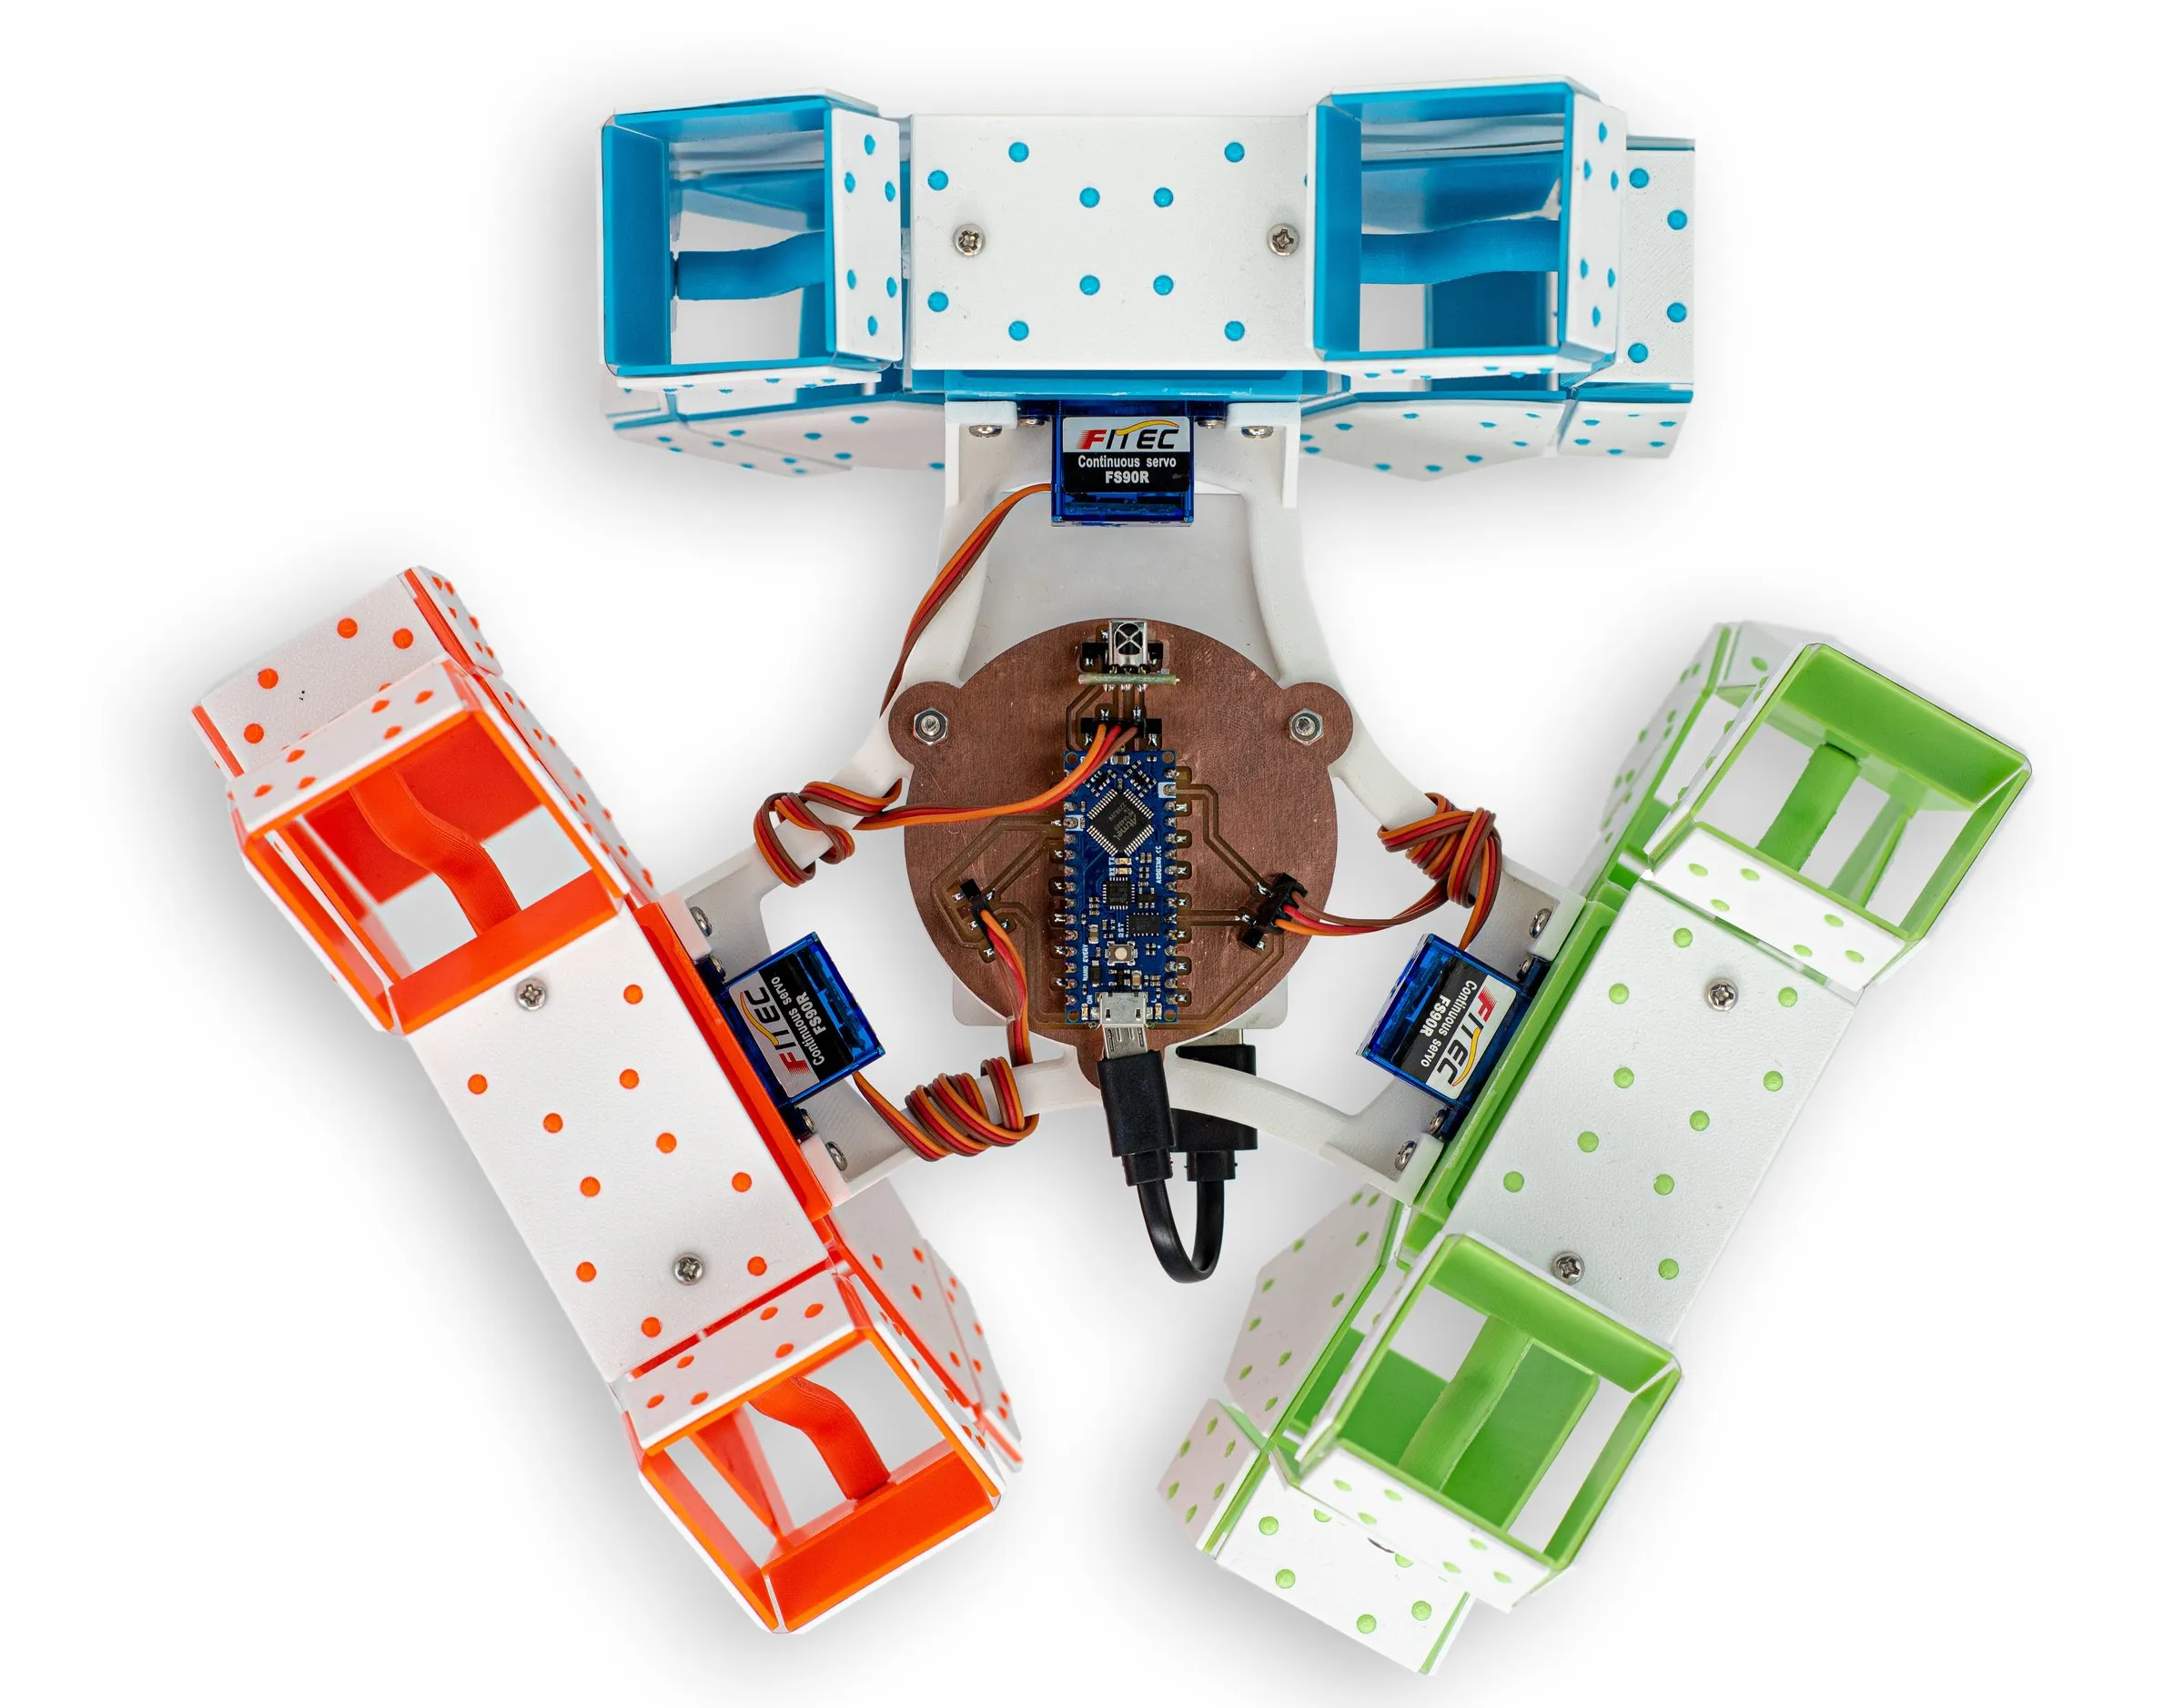
A walking robot made of folds and Mylar, not joints.